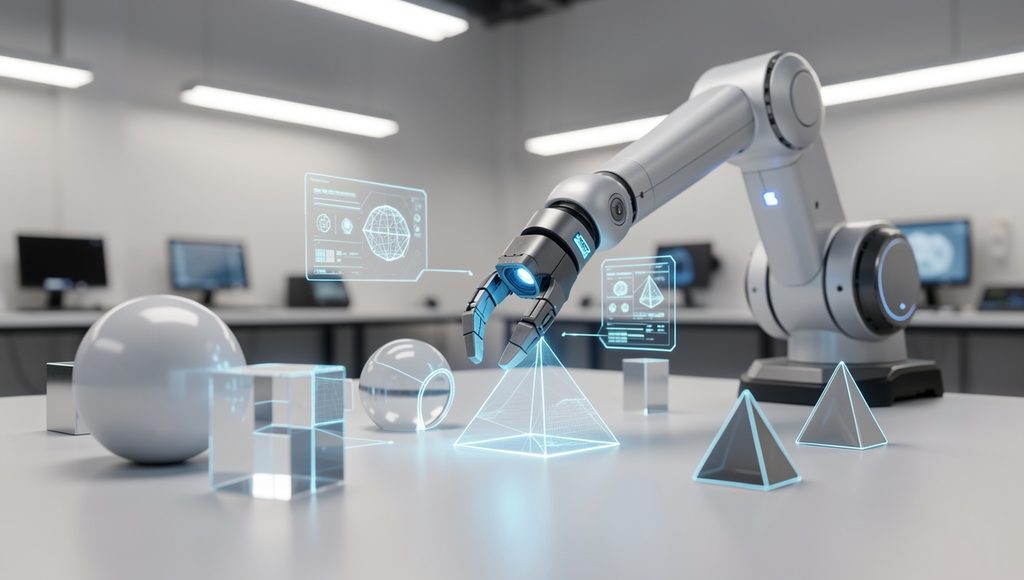
Shape Recognition for Robots
Understanding how robots identify and classify shapes using vision systems.
What Is Shape Recognition for Robots?
Shape recognition is an important capability in robotic vision that allows robots to identify objects based on their geometric characteristics. Instead of simply detecting that an object exists, a robot can analyze its outline, contours, edges, and proportions to determine whether it resembles a circle, square, triangle, rectangle, or another shape.
Shape recognition can help robots understand their surroundings and make decisions during tasks such as object sorting, navigation, inspection, assembly, packaging, and manipulation.
Why Shape Recognition Is Important
Robots often work in environments containing objects with different sizes, orientations, and geometric structures. Shape recognition gives a robot additional visual information that can be used to distinguish between objects.
Common Shapes Recognized by Robots
Circle
Recognized using curved contours and circular geometry.
Square
Identified by four approximately equal sides and corners.
Triangle
Identified using three connected edges and three corners.
Rectangle
Recognized through four sides and approximately right angles.
How Robots Recognize Shapes
A robotic vision system normally processes camera images through several stages. The exact process depends on the robot, camera, lighting, environment, and recognition algorithm.
Image Capture
A camera captures an image or video of the robot’s environment. The image becomes the input for the vision-processing system.
Image Preprocessing
The system can improve the image by reducing noise, adjusting brightness, or converting it into a suitable image format.
Edge Detection
Edges can be detected to identify boundaries between an object and its surrounding background.
Contour Analysis
The robot can examine object contours to estimate the number of edges, corners, curves, and other geometric properties.
Shape Classification
Extracted geometric features are compared with shape patterns to classify the detected object.
Robot Action
After recognizing the shape, the robot can use the result to select an appropriate movement or task.
Technologies Used for Shape Recognition
Computer Vision
Computer vision techniques allow robots to extract useful information from camera images. Edge detection, contour analysis, segmentation, feature extraction, and pattern analysis can all contribute to shape recognition.
Image Processing
Image processing prepares camera data for recognition. Operations such as thresholding, filtering, resizing, and edge extraction can make geometric features easier to identify.
Machine Learning
Machine learning can be used when shape recognition needs to work with complicated images or objects that do not have perfectly defined geometric boundaries.
Deep Learning
Deep learning models can learn visual patterns from large collections of images. They can be useful for recognizing shapes when lighting, background, orientation, or object appearance varies considerably.
Applications of Shape Recognition in Robotics
Object Sorting
Robots can classify objects according to their geometric shape and place them into appropriate locations.
Industrial Inspection
Vision-enabled robots can inspect manufactured components and identify shapes that differ from expected designs.
Robotic Pick-and-Place
Shape information can help a robot determine which object to pick and how the object should be approached.
Navigation
Robots can recognize geometric signs, markers, obstacles, or environmental features to support navigation.
Packaging
Robots can identify package shapes and use this information during handling, sorting, and placement.
Educational Robots
Educational robots can use shape recognition to interact with learning objects, cards, blocks, and geometric patterns.
Challenges in Shape Recognition
- Lighting: Shadows and changing illumination can make object boundaries difficult to detect.
- Object Orientation: A rotated object may appear different from its standard orientation.
- Occlusion: Partially hidden objects can be difficult to classify.
- Background Clutter: Complex backgrounds can interfere with edge and contour detection.
- Perspective: Objects can appear distorted when viewed from different camera angles.
- Similar Shapes: Different objects may have very similar geometric outlines.
Shape Recognition and Robot Decision-Making
Shape recognition becomes particularly useful when its results are combined with other visual information. A robot may analyze an object’s shape together with its color, size, location, texture, or orientation.
For example, a robot sorting system could identify a red circular object and a blue rectangular object as different targets. The robot can then use these visual characteristics to select an appropriate action.
Benefits of Shape Recognition
- Improves a robot’s visual understanding of objects.
- Supports automated object classification.
- Helps robots perform sorting and inspection tasks.
- Can improve object-handling decisions.
- Supports autonomous operation in structured environments.
- Can be combined with other robotic vision techniques.
Conclusion
Shape recognition is a useful part of robotic vision. By analyzing contours, edges, corners, curves, and other geometric characteristics, robots can identify different types of shapes in their environment.
When combined with image processing, computer vision, machine learning, and other sensing technologies, shape recognition can help robots perform increasingly intelligent tasks in manufacturing, logistics, education, inspection, and autonomous systems.
Explore Robotics Engineering Courses